Team NimbRo Wins Best Paper Award with Fast Robot Image Annotation
Team NimbRo secured third place at RoboCup 2026 and won the best paper award for a new method that helps robots learn objects quickly.
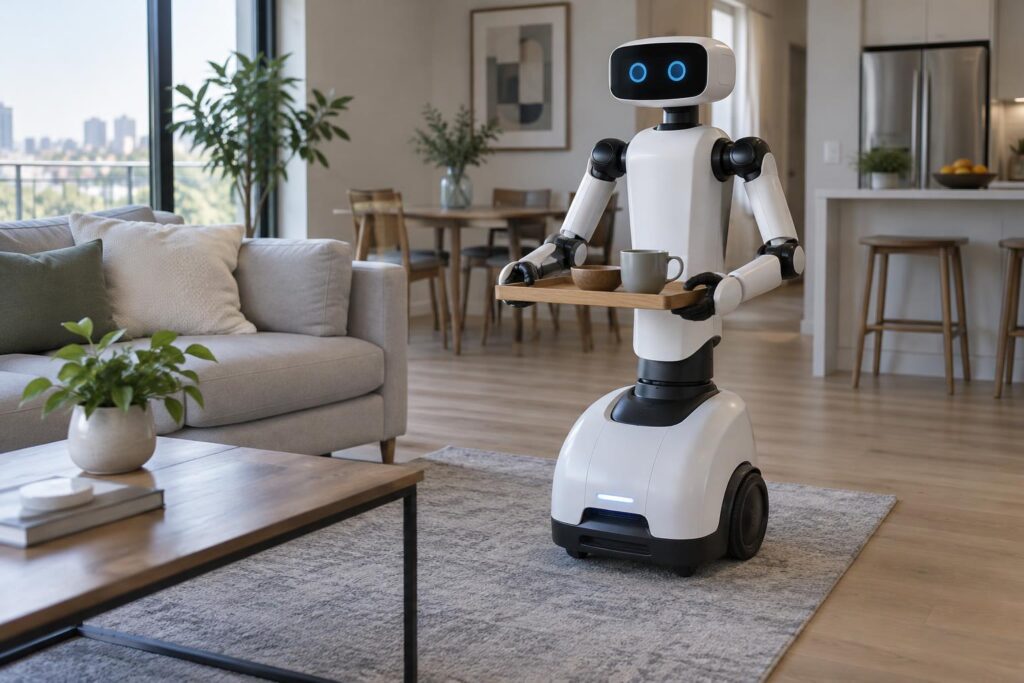
Raphael Memmesheimer leads Team NimbRo, a group that has won the RoboCup@Home competition five times. The team recently earned the best paper award at RoboCup 2026 for their research on efficient image annotation. The work helps robots quickly learn new objects in unfamiliar environments during tight preparation windows.
The Challenge of Unfamiliar Environments
Teams arriving at RoboCup competitions receive only two days to assemble their robots and adapt them to a model apartment. Organisers source local groceries and items from shops near the venue, meaning teams cannot fully anticipate the exact objects their machines will encounter. Up to fifty different unknown items can appear in the apartment, requiring fast vision model generation so the robots can interact with them.
Semi-Supervised Labeling and Competition Tasks
To solve this, Team NimbRo developed a multi-stage approach combining general object segmentation with semi-automatic labeling using reference images. This method automatically labels roughly sixty percent of the data, saving hours of manual human work. The improved vision model allowed the team to focus on testing tasks, leading to a third-place finish overall and a top performance in a new laundry task that involved opening a washing machine and folding t-shirts.
How does this story land?
One tap per reader.
Quick poll
Would you trust a household robot to fold your laundry today?
One vote per reader. Results show after you vote.
Ask this story
Answers are written by AI from this story only. They can be wrong.