Physicl raises $10M to build realistic 3D simulations for training robots
Physicl secures $10 million in seed funding to help robot builders train physical AI models using high-fidelity 3D simulations.
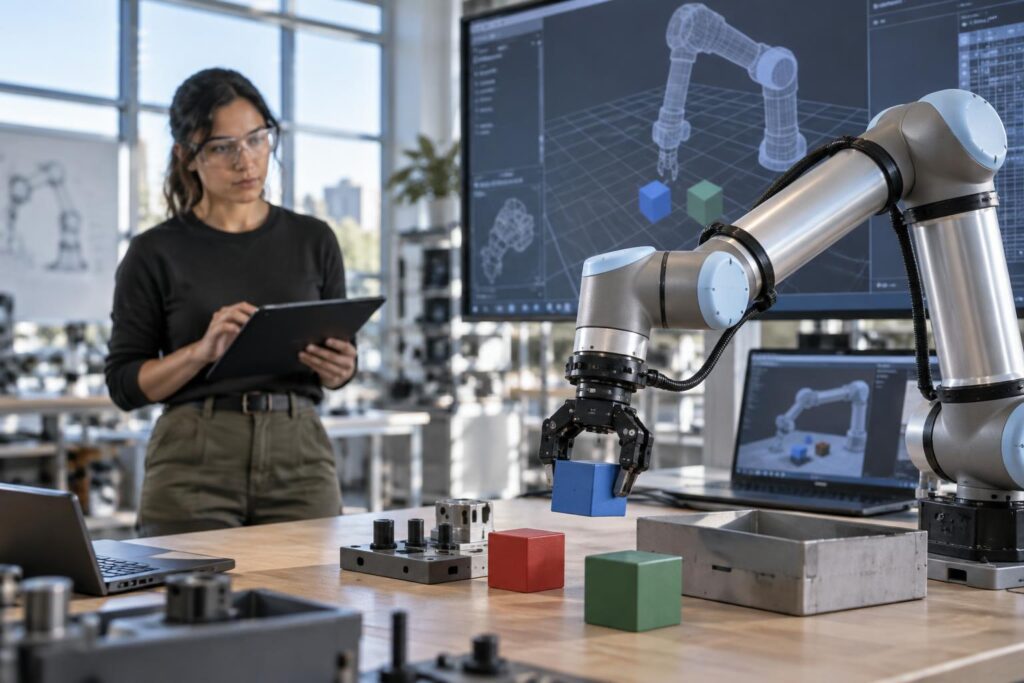
A new startup named Physicl has secured $10 million in seed funding to help robot builders solve training challenges. Inovia Capital led the funding round. Founder and CEO Alex de Vigan previously spent a decade building a platform that created 3D product models for e-commerce. When generative artificial intelligence changed that market, he realized his team’s technology could be repurposed to help robots understand physical space.
Training robots with synthetic data
Researchers trying to make robots handle everyday objects often struggle with training limitations. Training models on real video can be inefficient, and gathering data through remote operations is expensive. Digital simulations offer a promising alternative, but making those virtual worlds obey real-world physics is difficult. Physicl aims to use its 3D rendering pipeline to turn unstructured real-world information into accurate physical representations.
The Physicl Studio platform
The company is launching a product called Studio. It includes thousands of 3D environments and assets to help users generate synthetic data for specific problems. For instance, the software can help train a robot to find an object on a cluttered counter. Early customers like world model builder SpAItial are already using these tools to improve the quality of their 3D simulations derived from flat images.
- Physicl raised $10 million in seed funding led by Inovia Capital.
- The company launched Studio with thousands of 3D environments and assets.
- Early partners use the platform to generate synthetic training data for robots.
How does this story land?
One tap per reader.
Quick poll
Are 3D simulations enough to train real-world robots?
One vote per reader. Results show after you vote.
Ask this story
Answers are written by AI from this story only. They can be wrong.